Safe Learning & Trustworthy Autonomy
We develop learning-based control and planning frameworks that enable autonomous systems to operate safely and reliably in uncertain, dynamic environments. Our research integrates reinforcement learning, safety-critical control, uncertainty quantification, and risk-aware decision-making to provide trustworthy autonomy with formal safety guarantees.
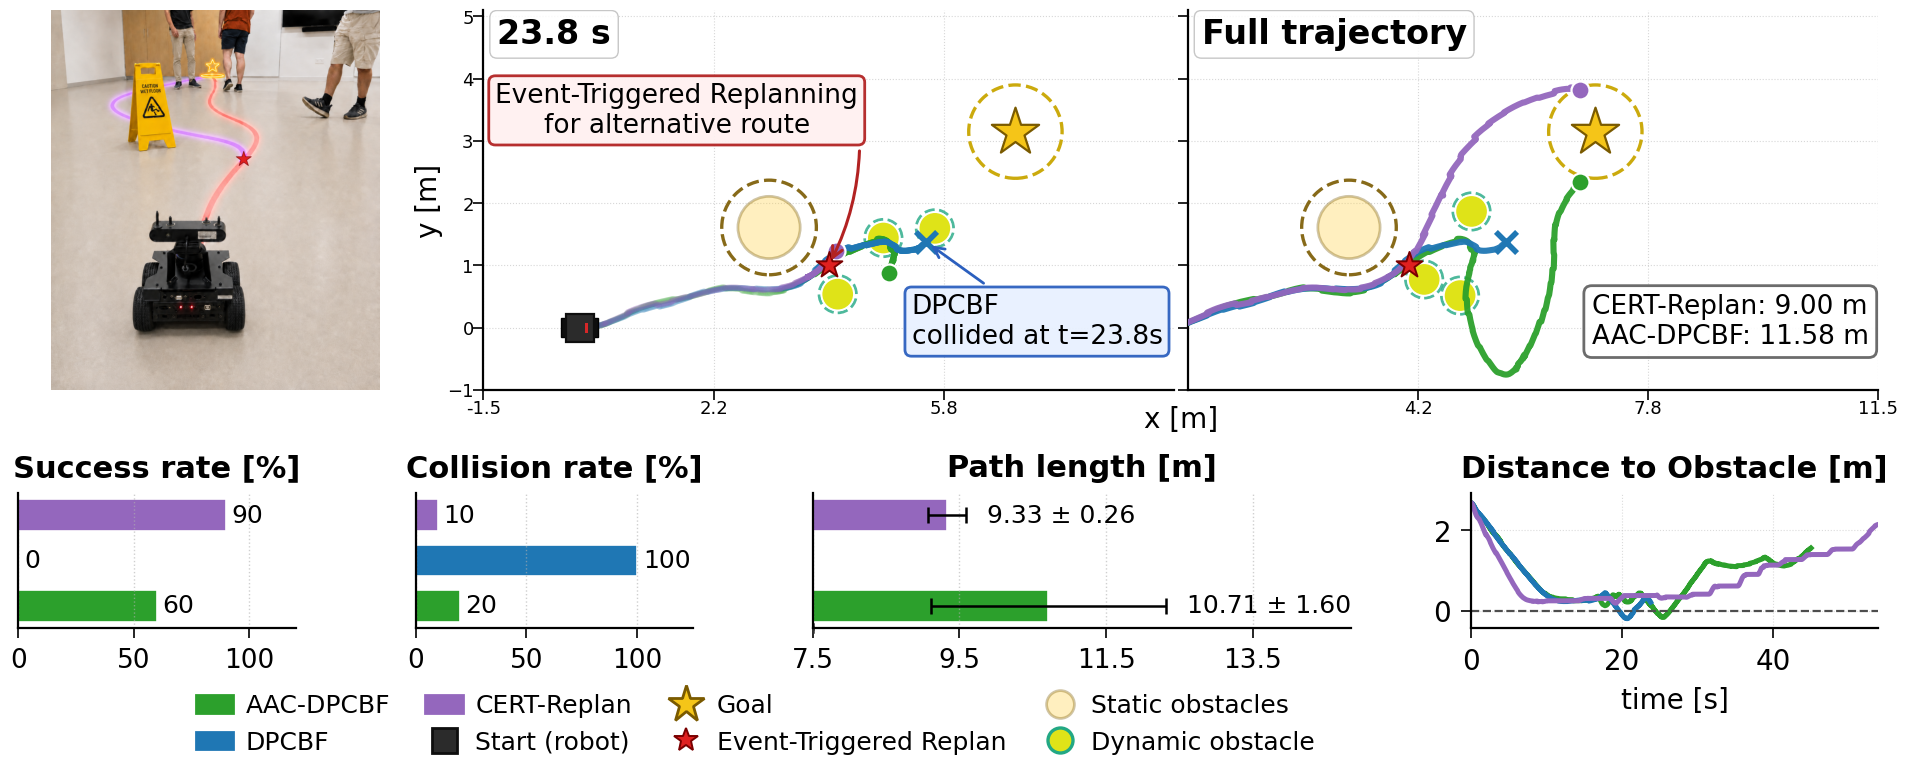
- Risk-certified, event-triggered replanning for navigation among moving obstacles
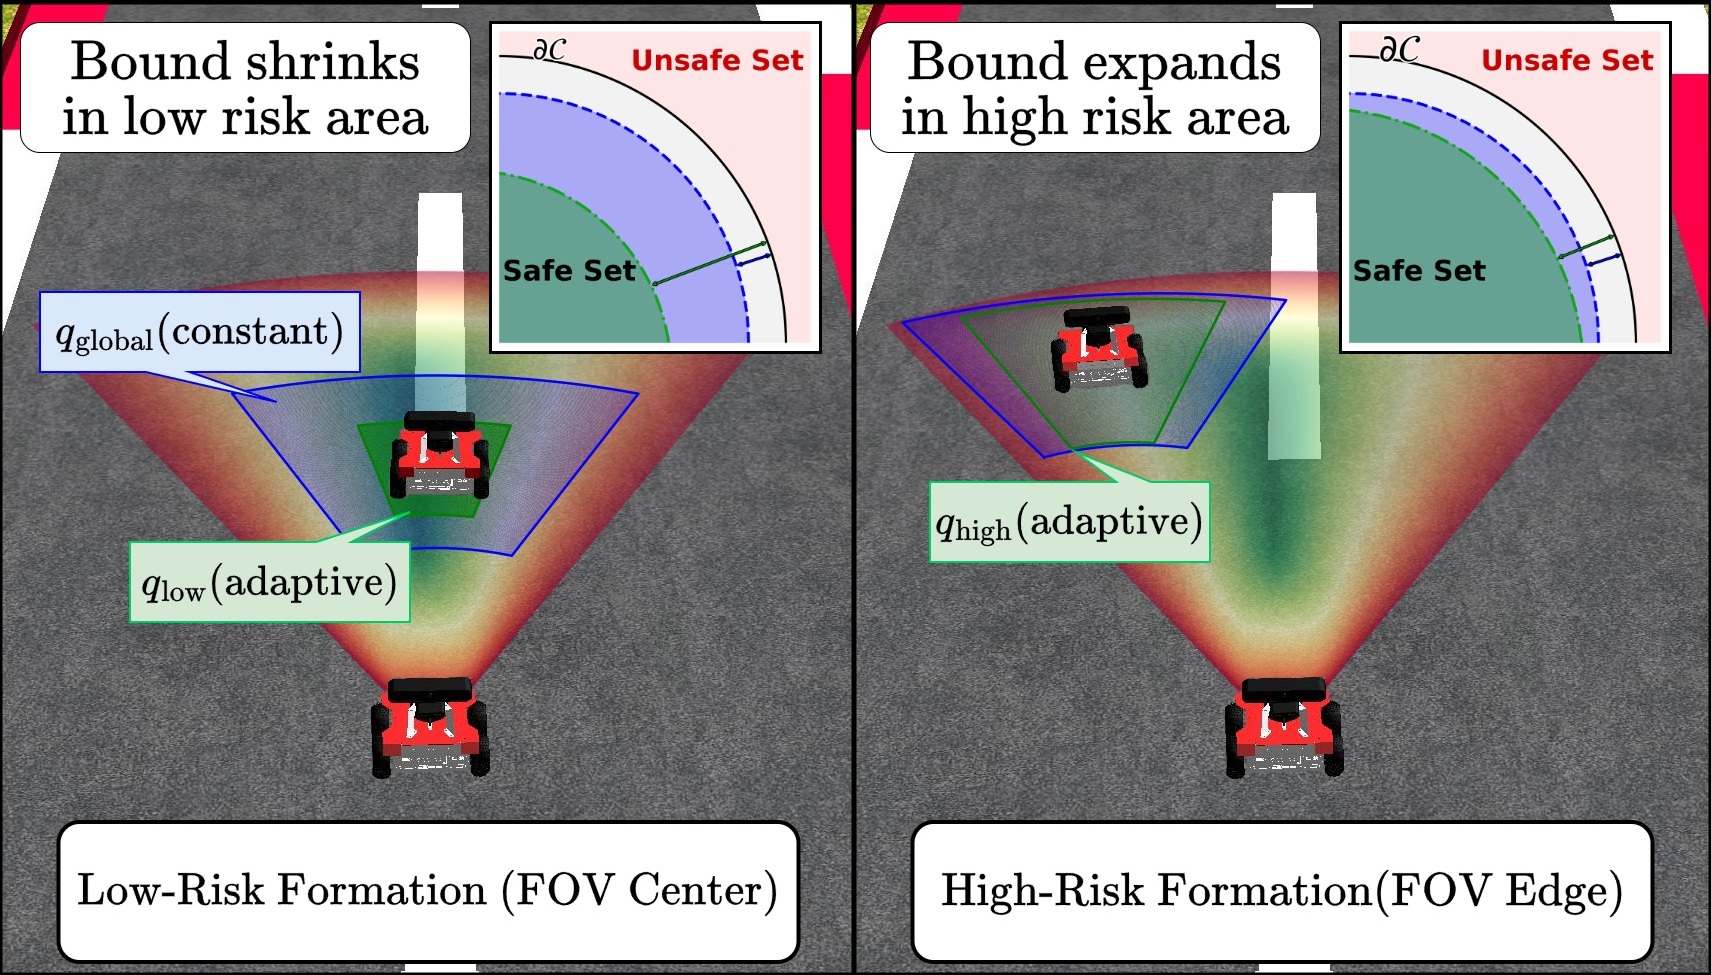
- Control barrier function safety filters for mobile robots and multi-robot teams
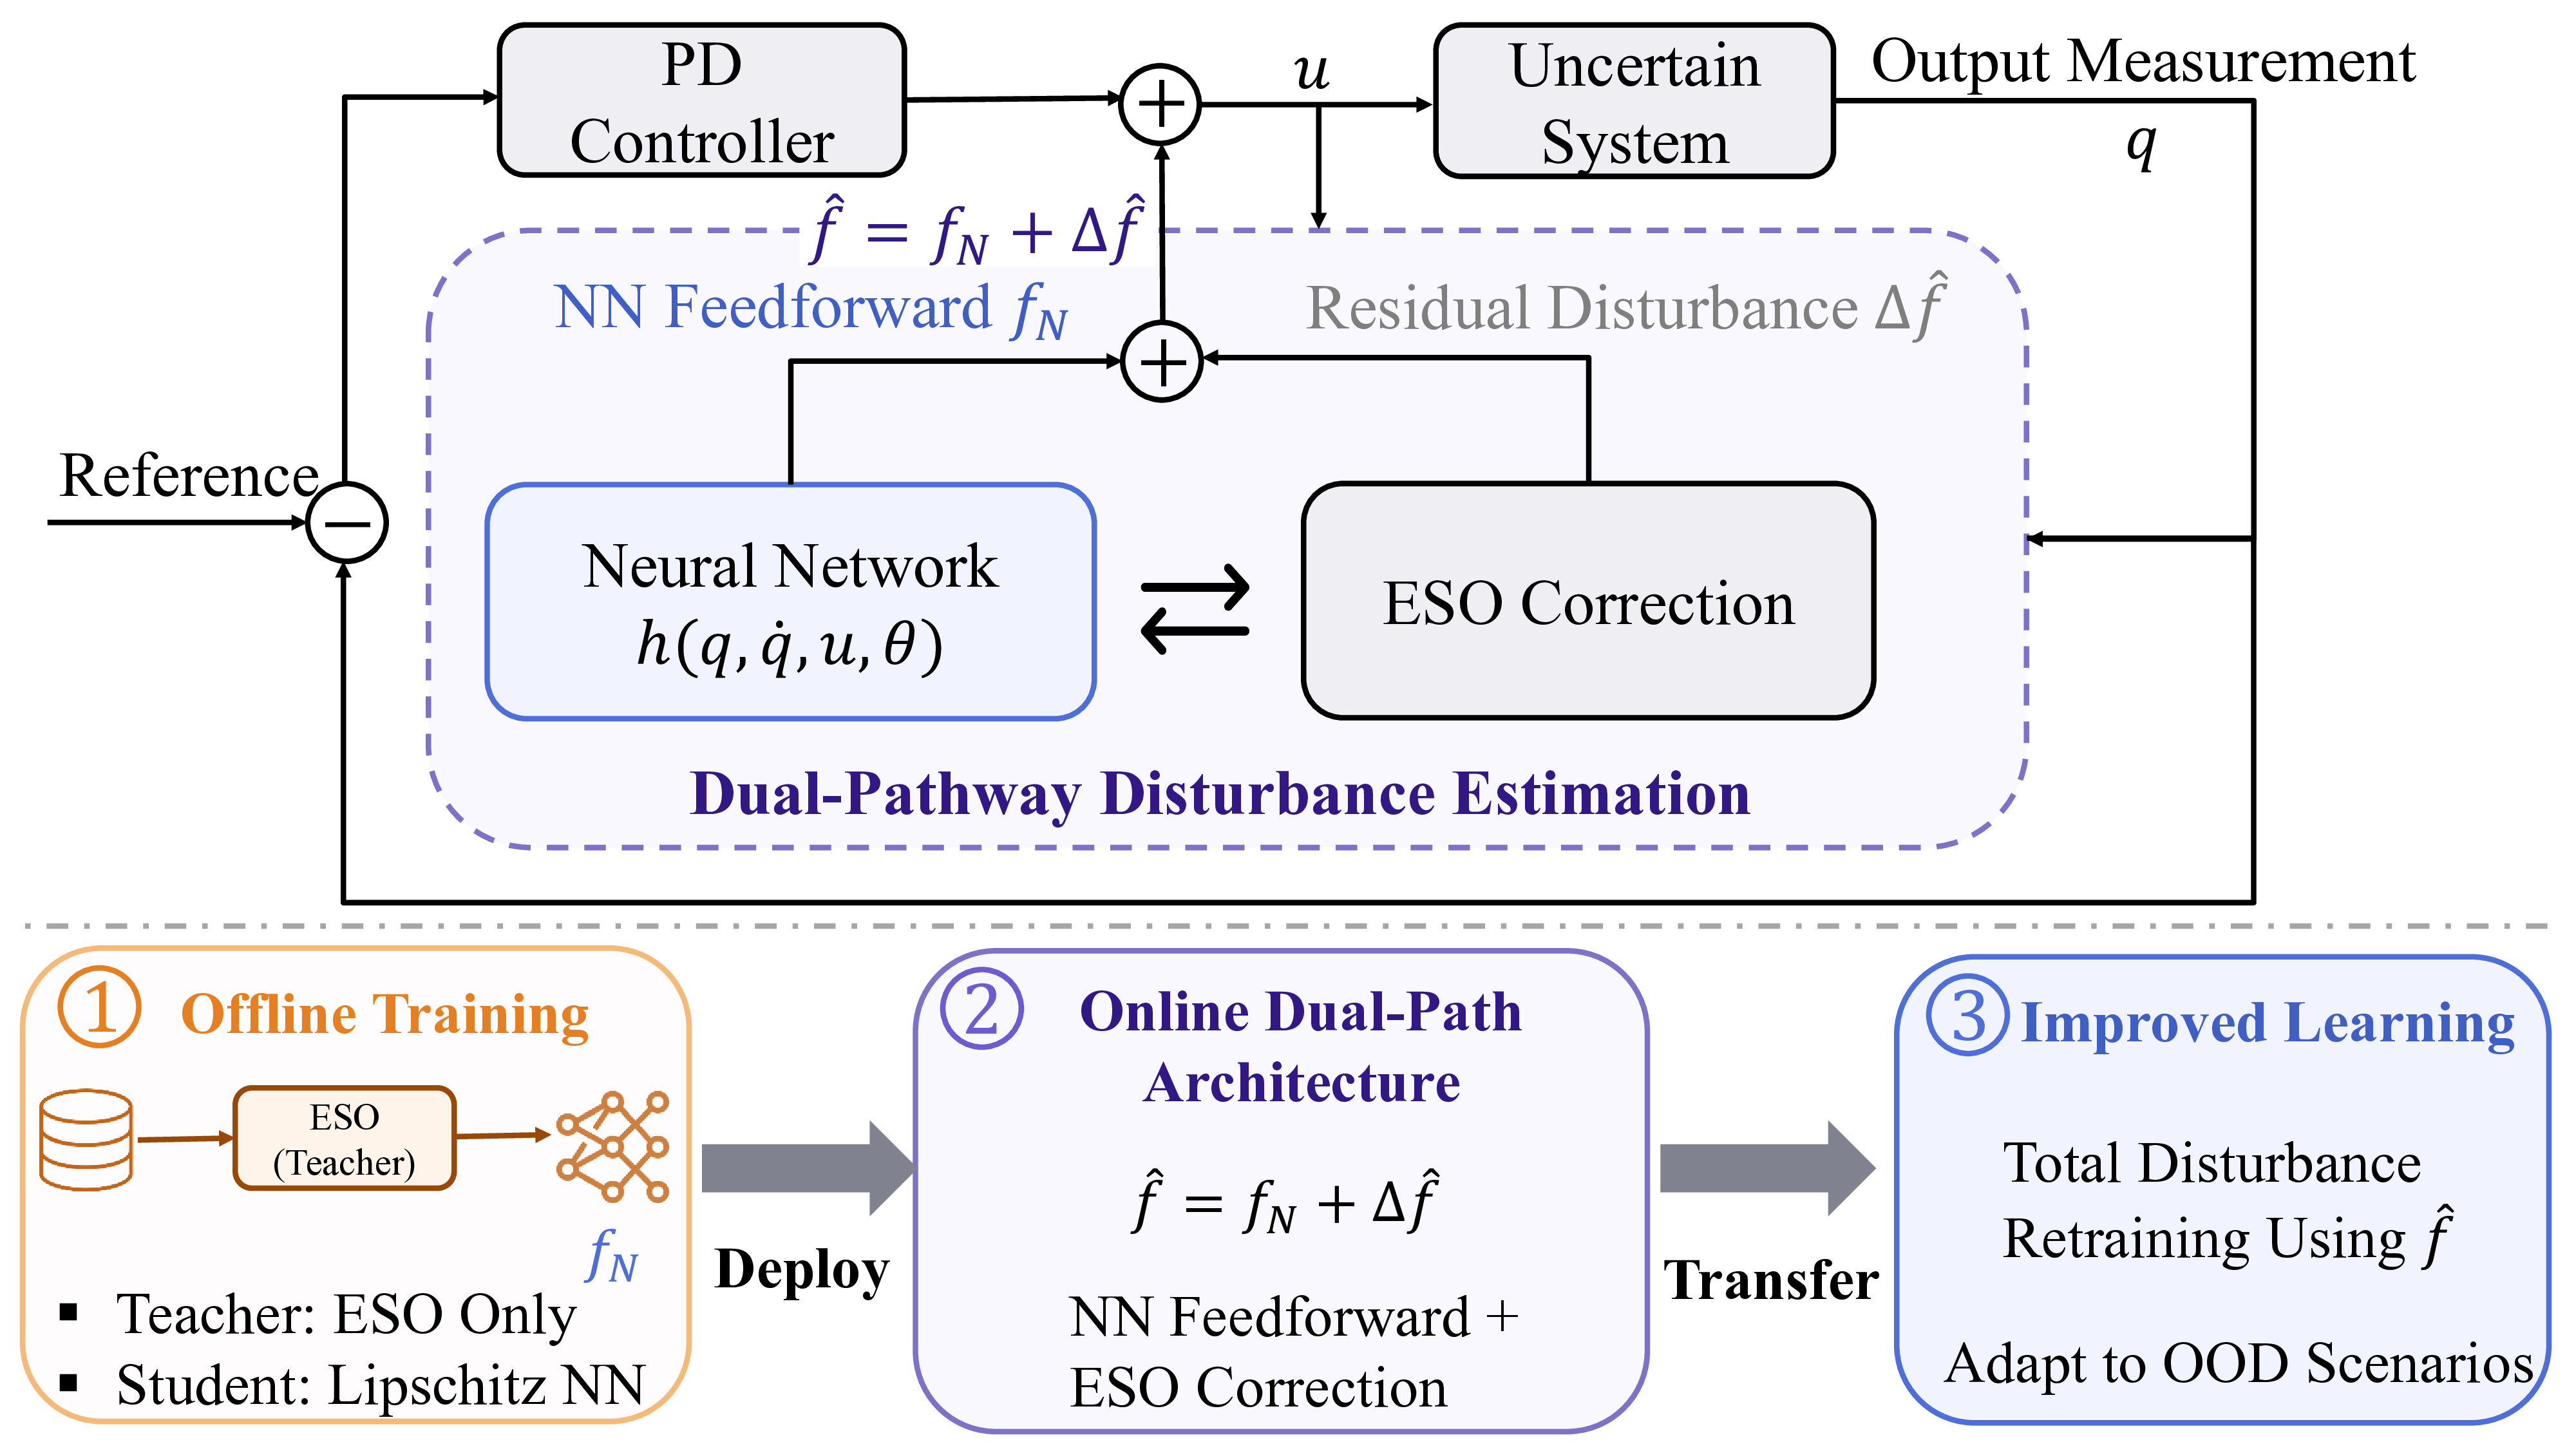
- Learning-based disturbance estimation with provable robustness
- Stochastic safety guarantees for systems that rely on unreliable communication
Representative publications
Lab members are in bold. ★ PhD student, ♦ Master's student, † equal contribution. The full list is on the Publications page.
2026
2025
2024
- IEEE CSLQuadrotor Fault-Tolerant Control at High Speed: A Model-Based Extended State Observer for Mismatched Disturbance Rejection ApproachIEEE Control Systems Letters (IEEE CSL), 2024
2021
- ACCOn a notion of stochastic zeroing barrier functionIn 2021 American Control Conference (ACC), 2021
2019
- AUTOMCo-design of safe and efficient networked control systems in factory automation with state-dependent wireless fading channelsAutomatica (AUTOM), 2019
2015
- IEEE TACDistributed switching control to achieve almost sure safety for leader-follower vehicular networked systemsIEEE Transactions on Automatic Control (IEEE TAC), 2015