Efficient Edge AI & Intelligent Perception

We develop resource-efficient machine learning and perception algorithms that bring advanced AI capabilities to embedded and robotic platforms. Our research emphasizes hardware-aware neural architecture search, energy-efficient computer vision, model optimization, and real-time edge intelligence for autonomous systems with limited computing resources.

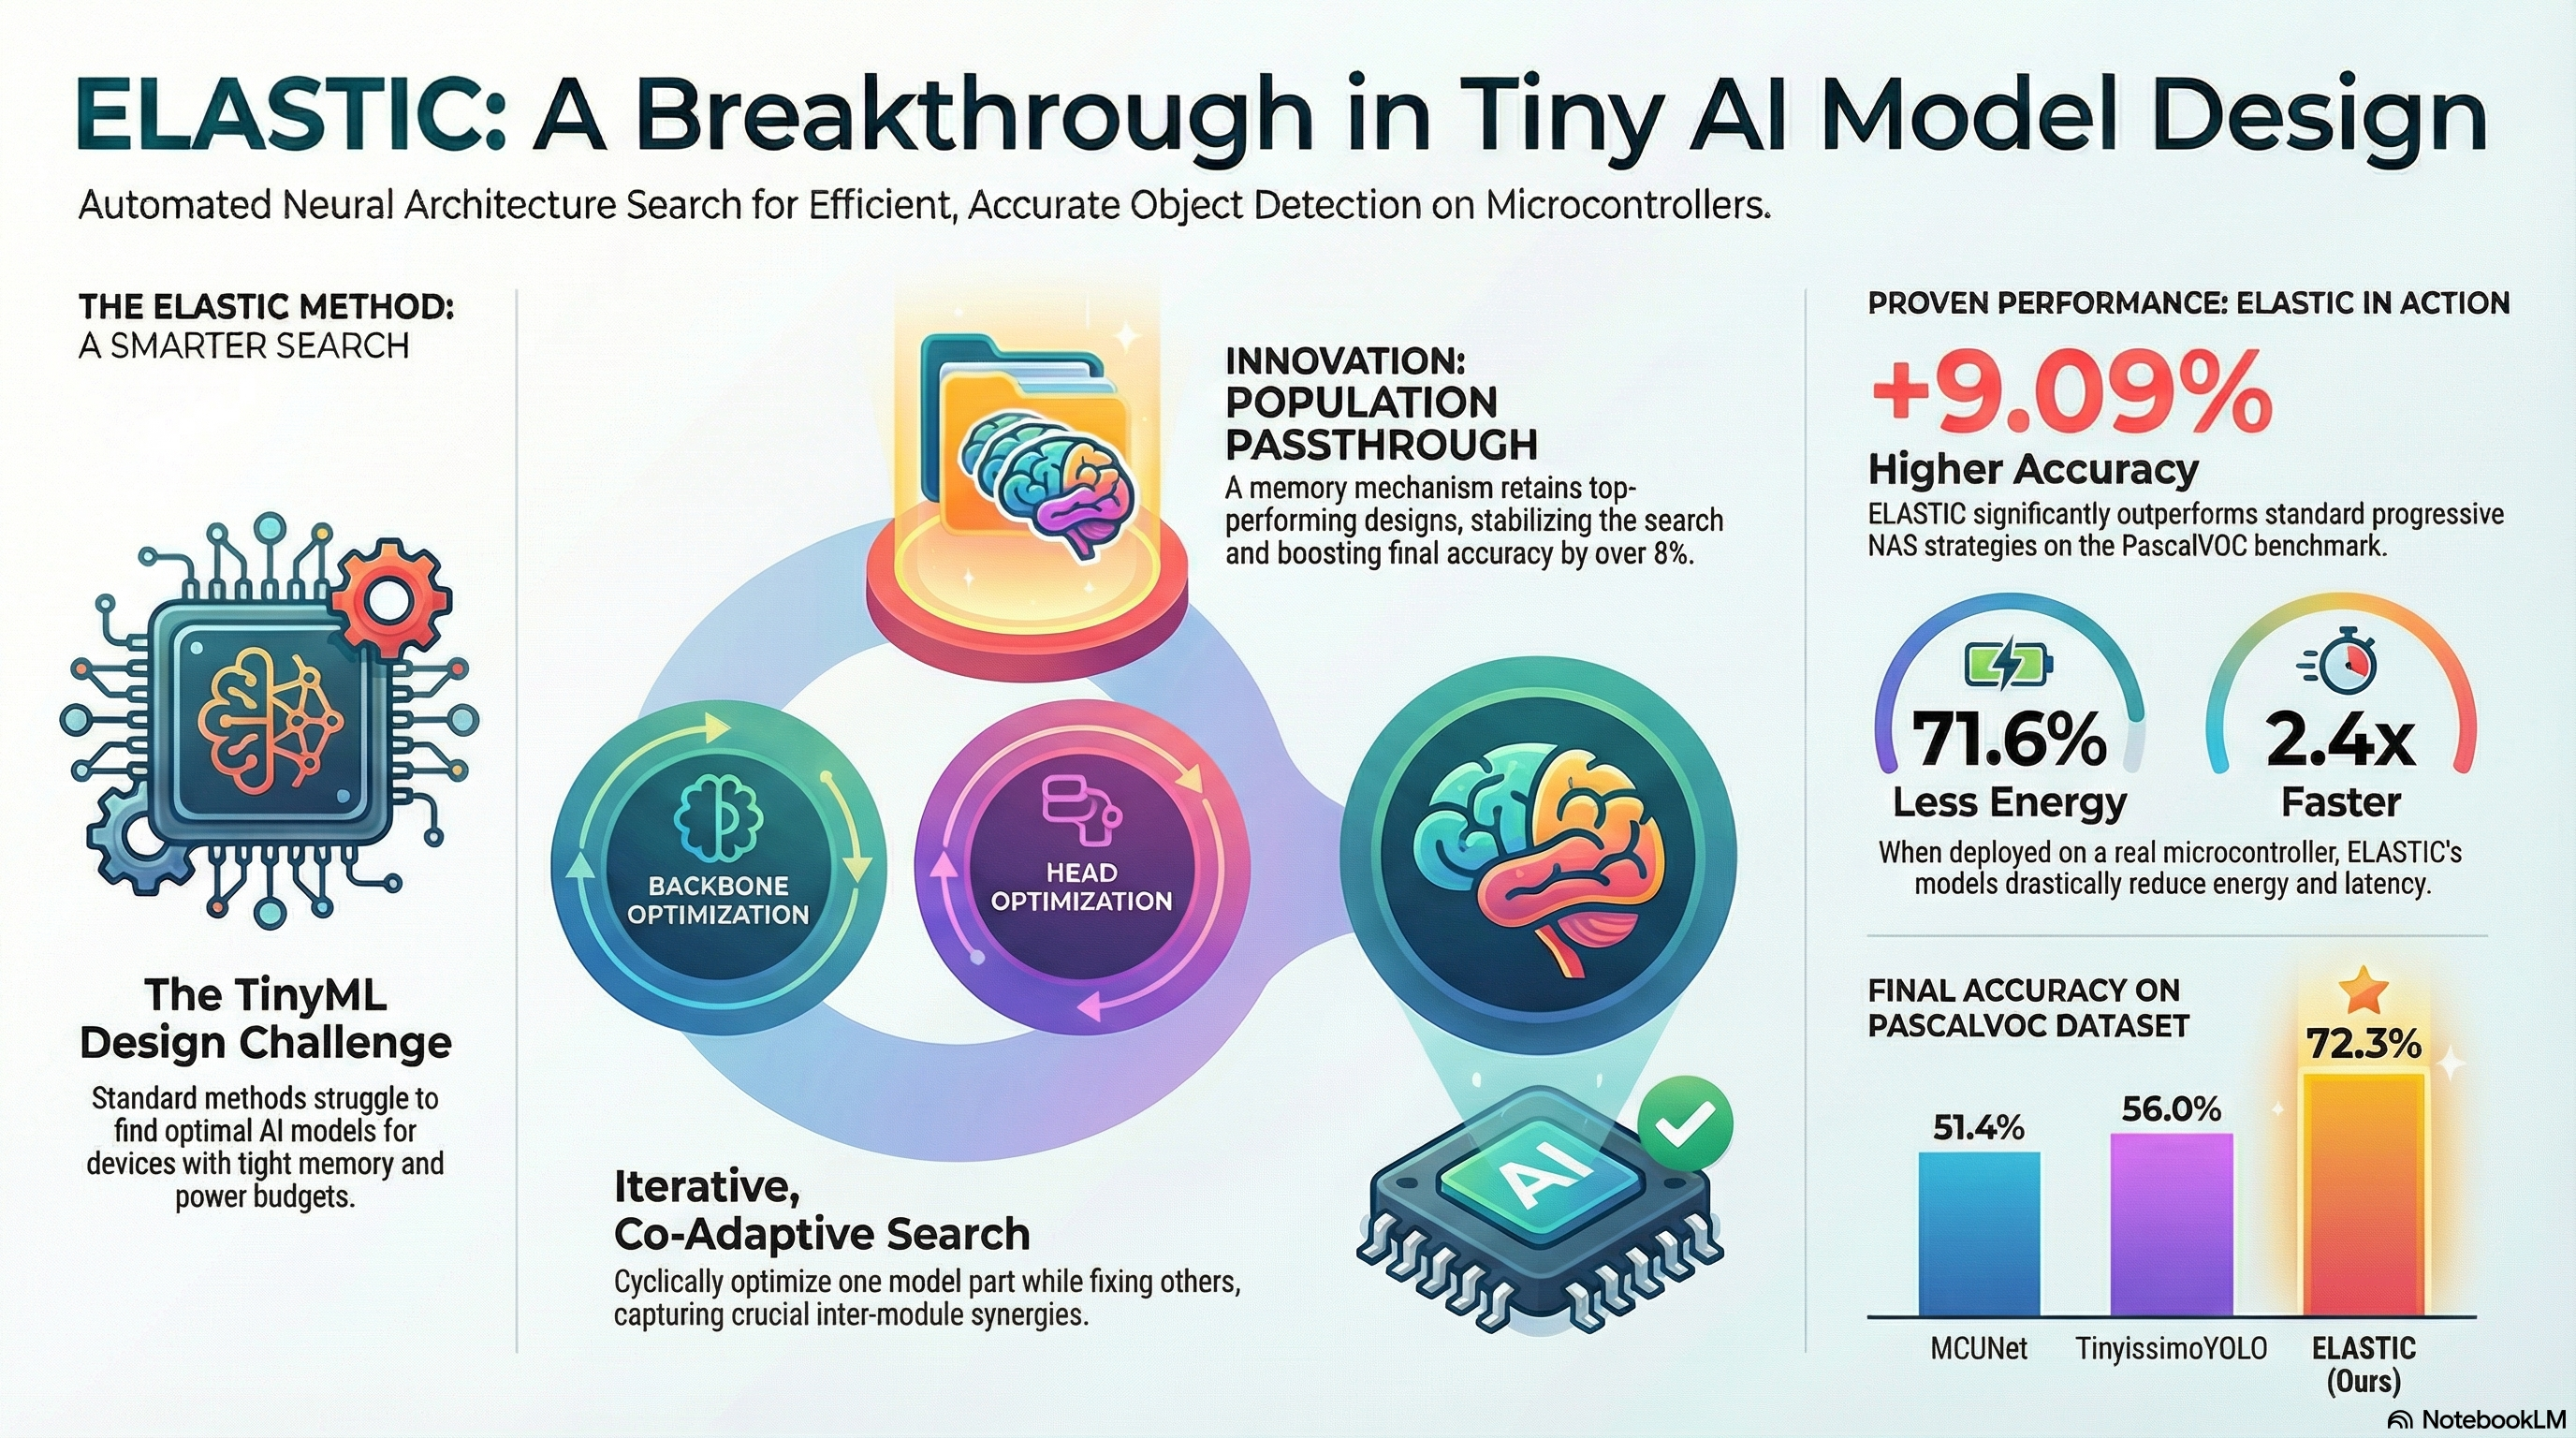
  • Hardware-aware neural architecture search for object detection on microcontrollers
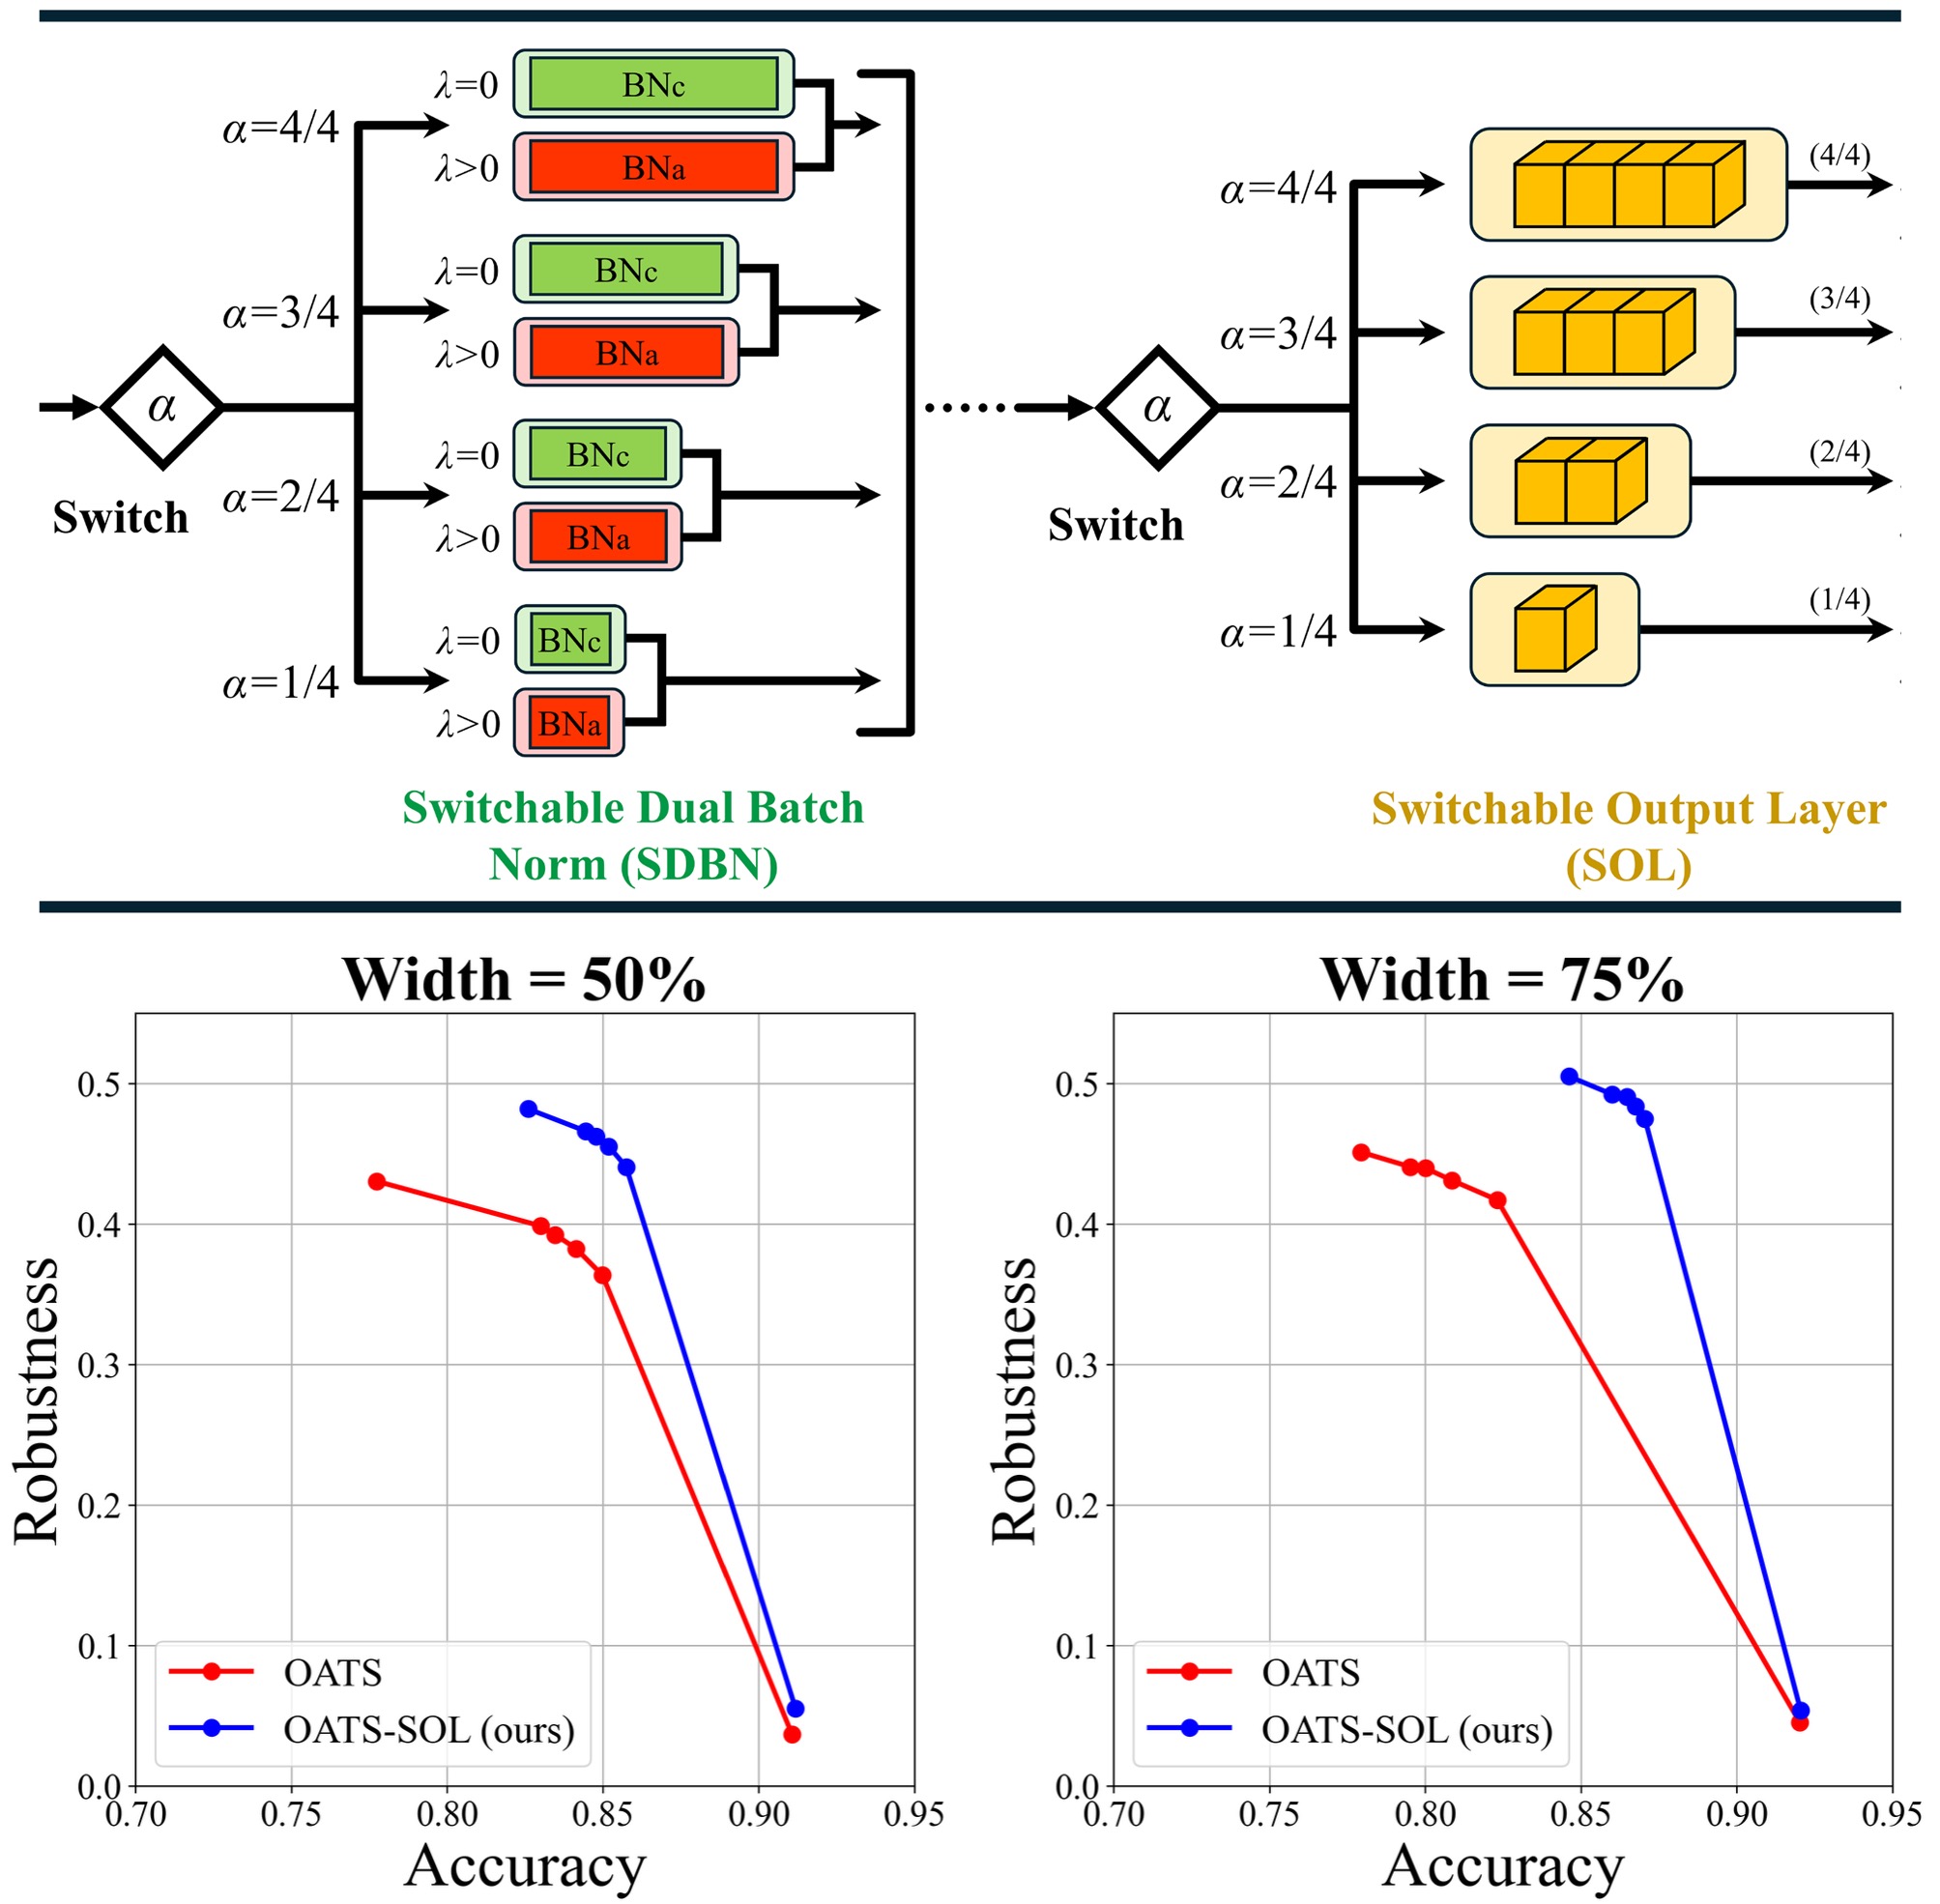
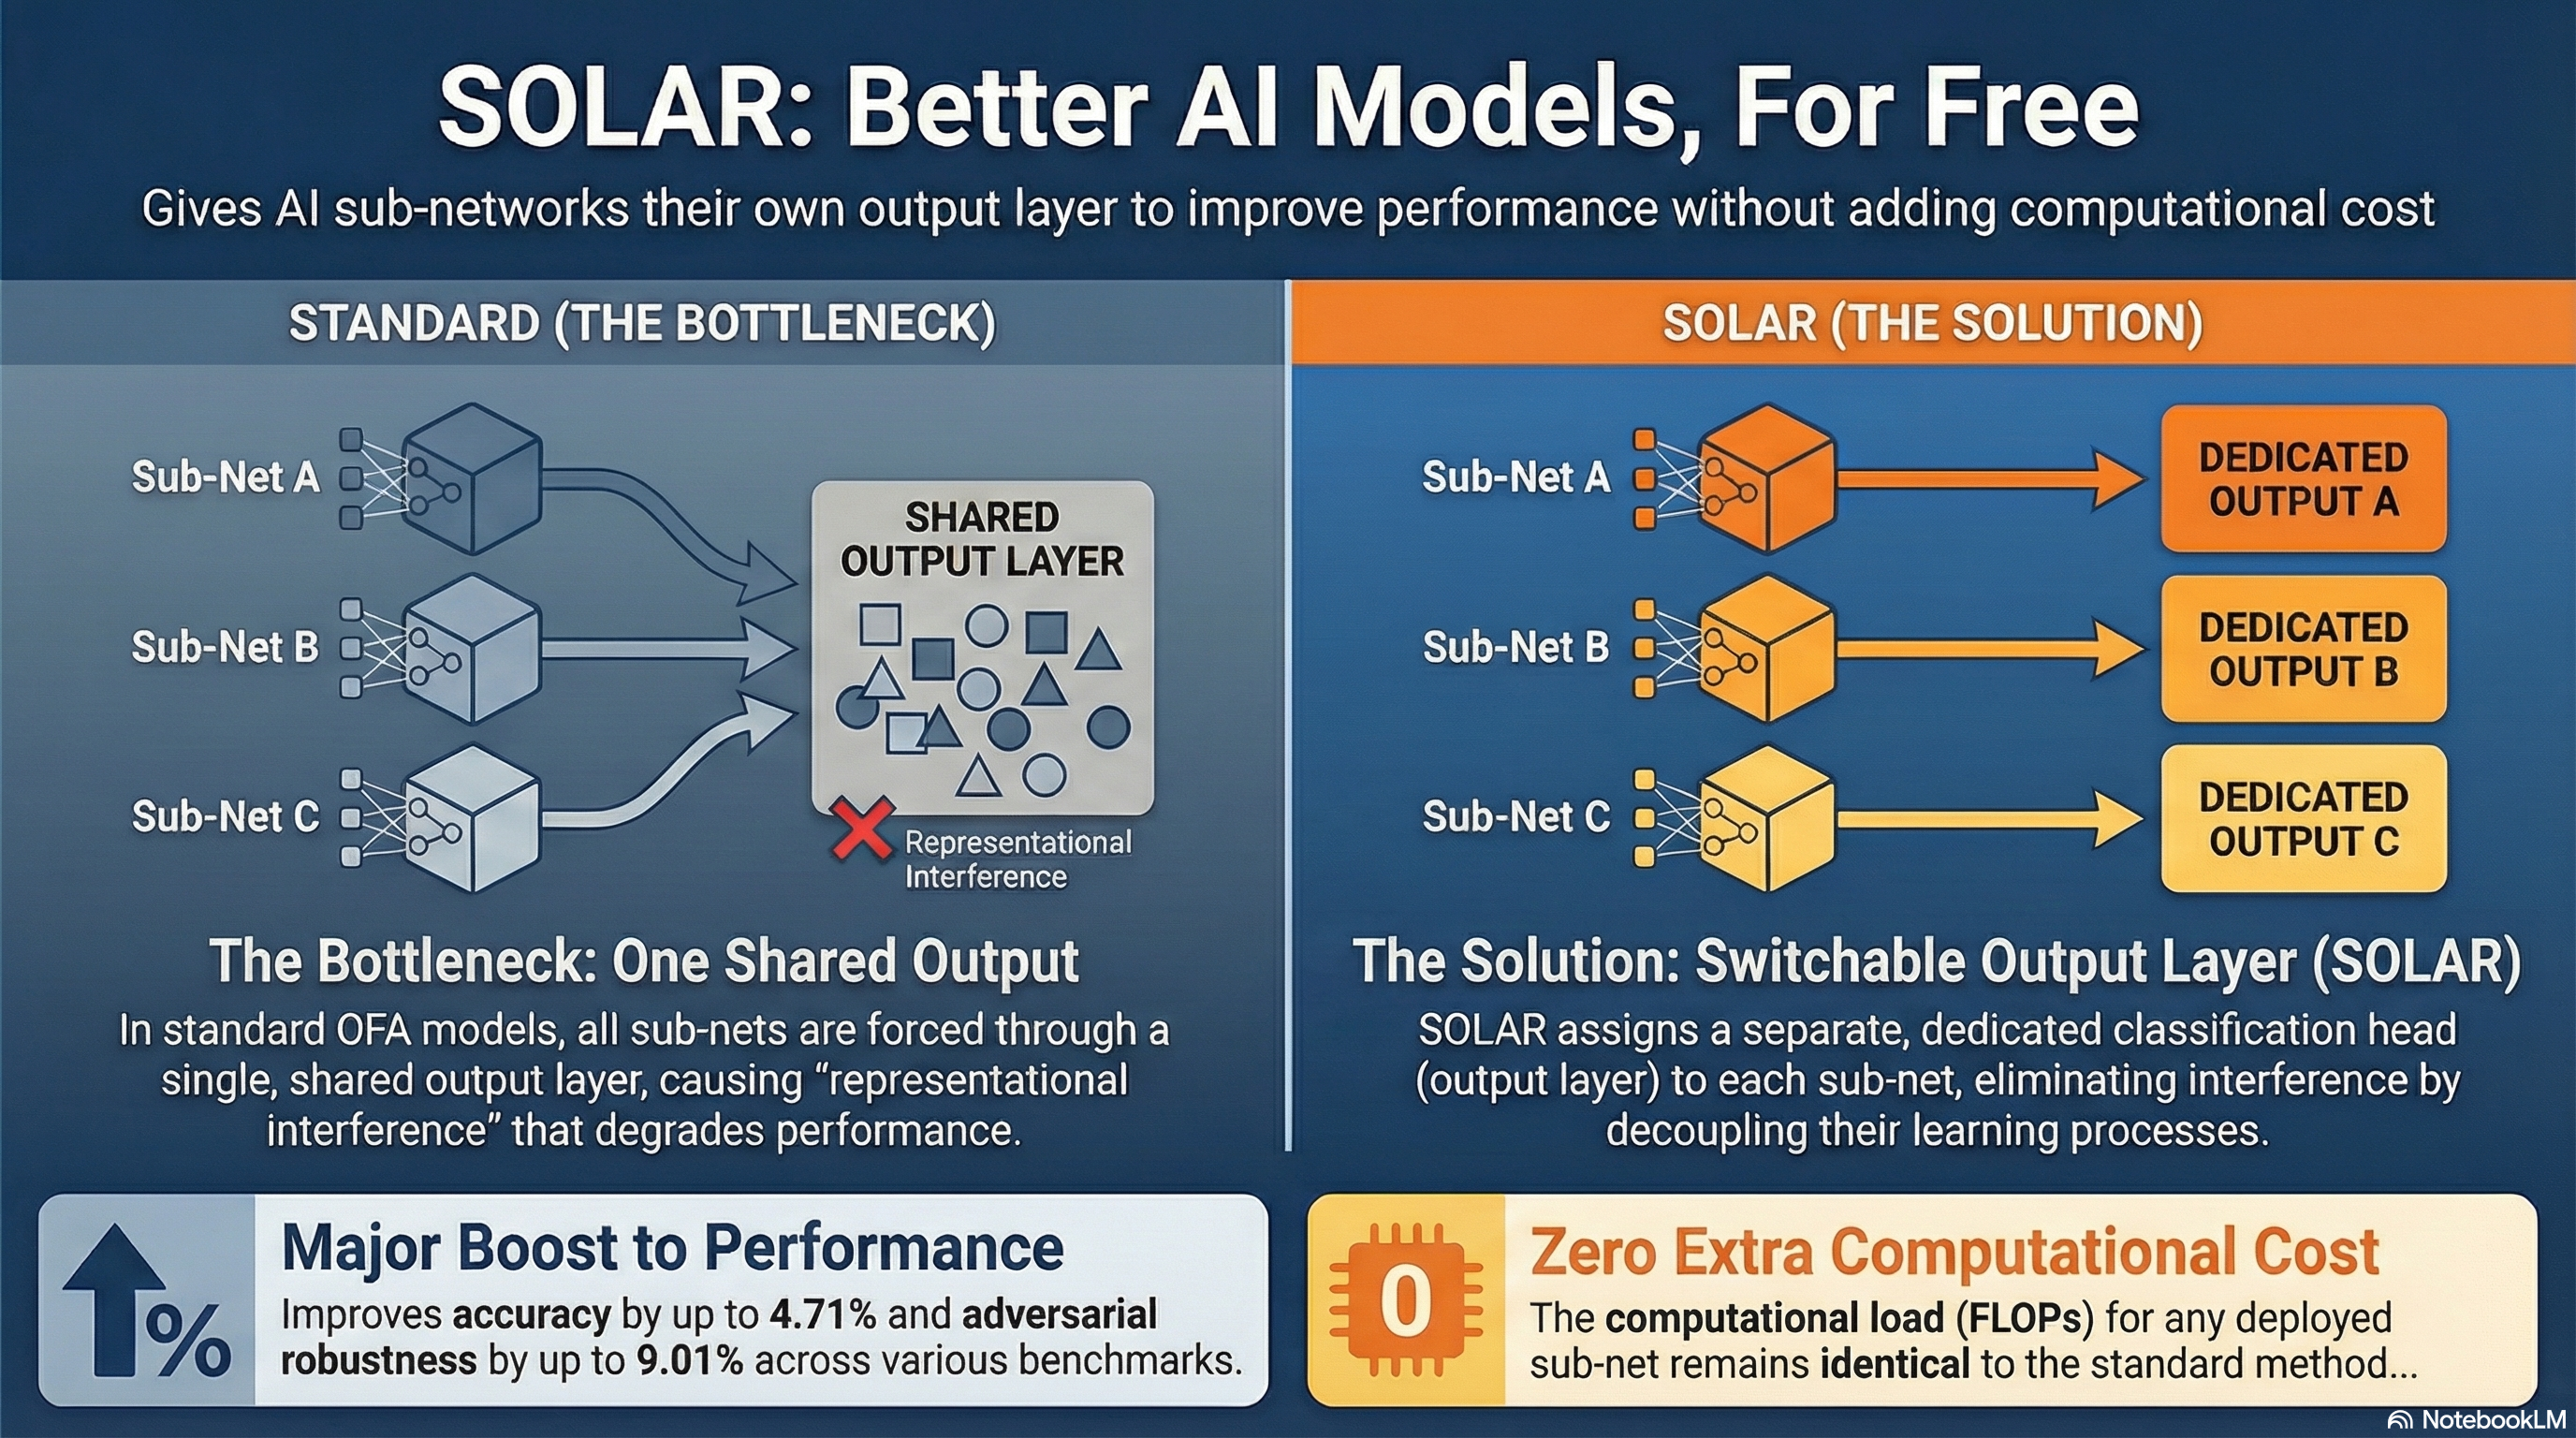
  • Once-for-all training that trades accuracy and robustness at run time
  • Efficient waste detection for multi-robot clean-up
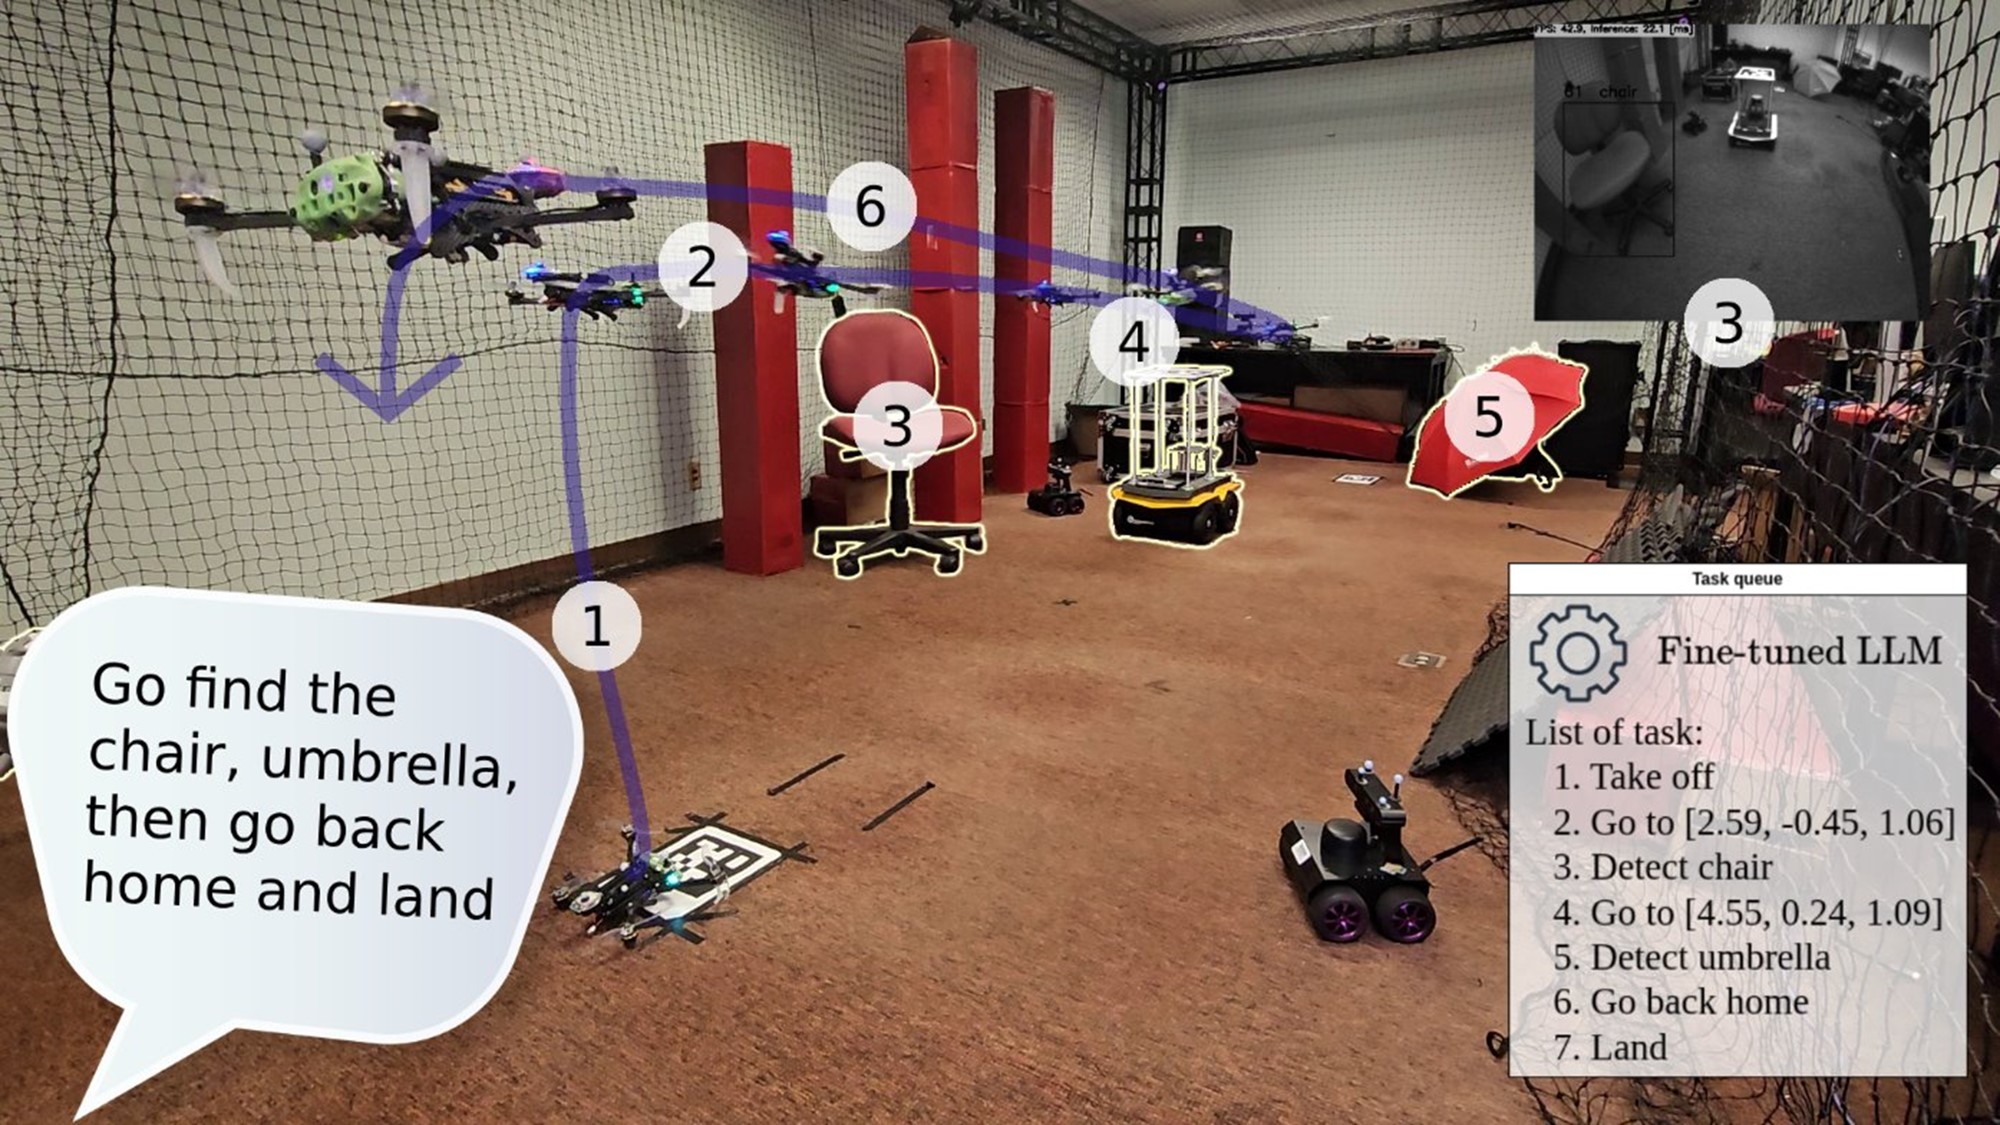
  • Embedded language-model guidance and energy-aware learning on mobile devices
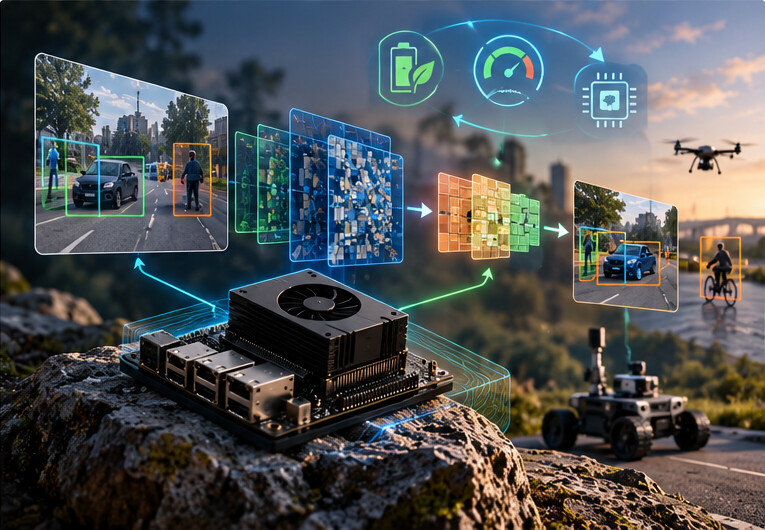
A compact edge-AI computer on a rock runs a camera-based detection pipeline, drawn as feature maps that turn a street scene into labeled detections, with icons for energy, speed, and the chip; a drone and a ground robot work nearby.

Representative publications

Lab members are in bold. ★ PhD student, ♦ Master's student, † equal contribution. The full list is on the Publications page.

2026
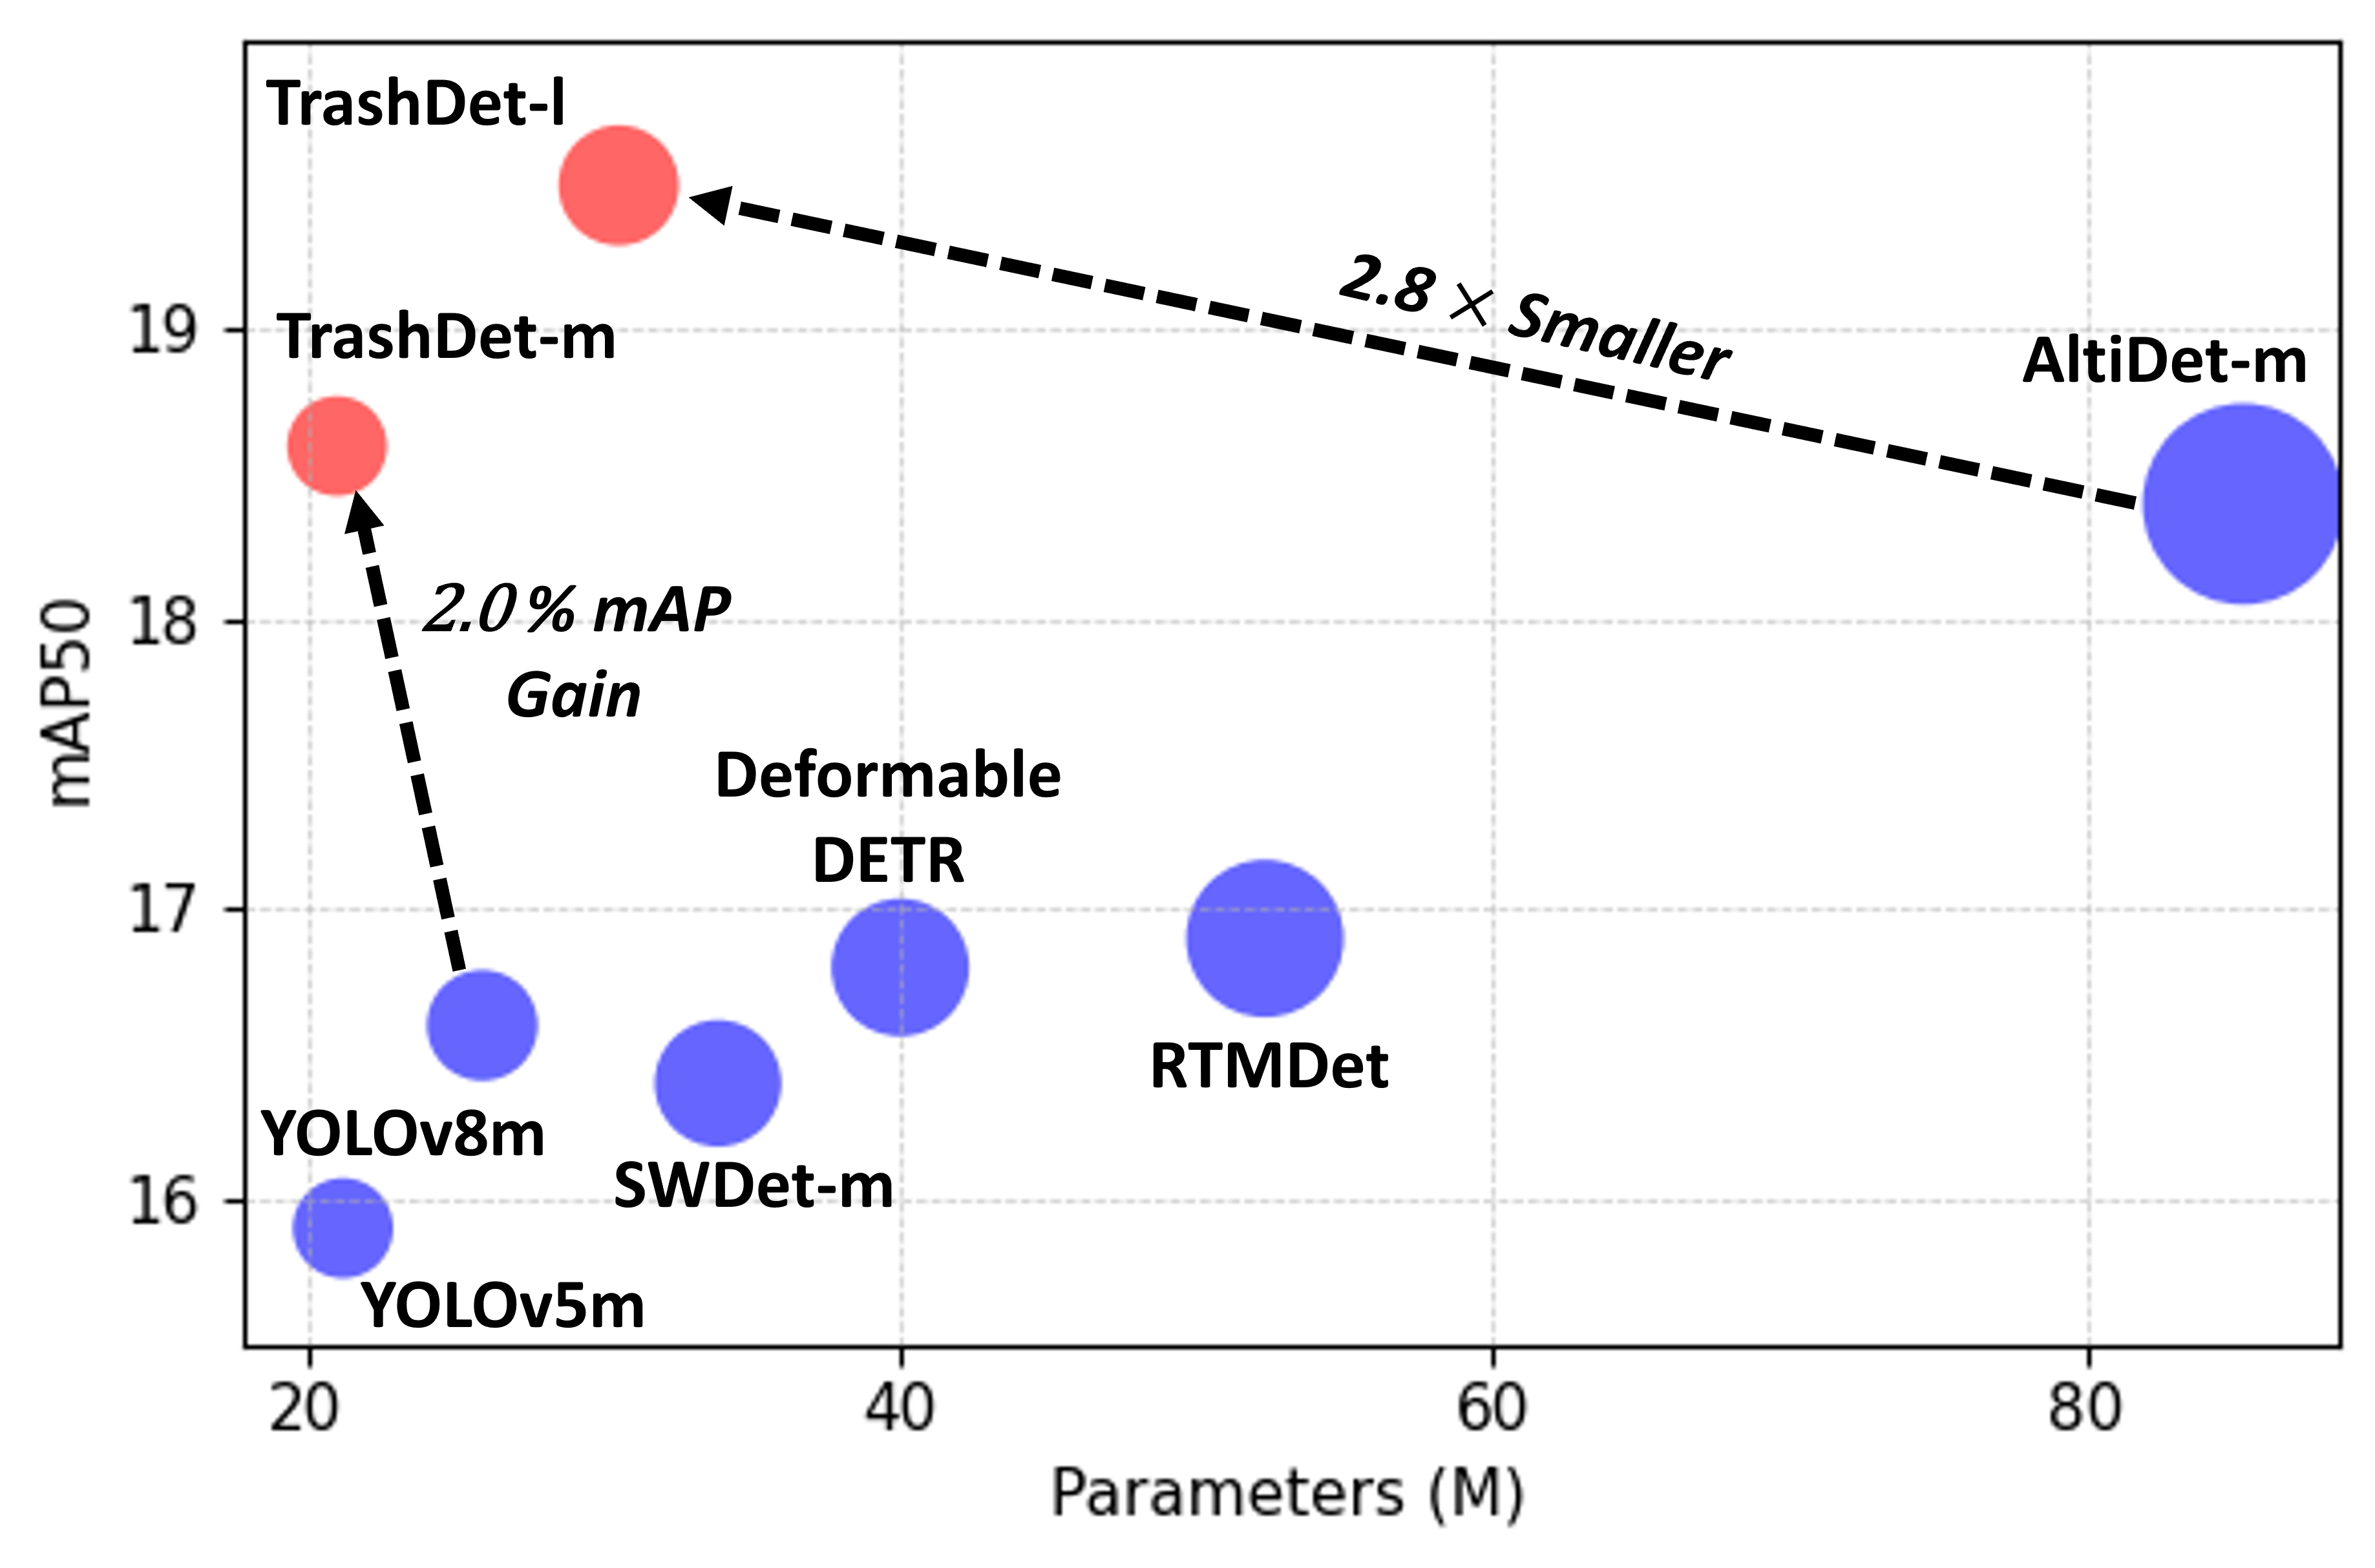
  1. Figure from TrashDet: Iterative Neural Architecture Search for Efficient Waste Detection
    WACV-WS
    TrashDet: Iterative Neural Architecture Search for Efficient Waste Detection
    Tony Tran♦ and Bin Hu
    In WASTEVISION: International Workshop on Smart Waste Monitoring at IEEE/CVF Winter Conf. on Applications of Computer Vision (WACV-WS), 2026
  2. IEEE TC
    ELASTIC: Efficient Once For All Iterative Search for Object Detection on Microcontrollers
    Tony Tran♦, Qin Lin, and Bin Hu
    IEEE Transactions on Computers (IEEE TC), 2026
  3. Figure from SOLAR: Switchable Output Layer for Accuracy and Robustness in Once-for-All Training
    WACV
    SOLAR: Switchable Output Layer for Accuracy and Robustness in Once-for-All Training
    Shaharyar Ahmed Khan Tareen★, Lei Fan, Xiaojing Yuan, Qin Lin, and Bin Hu
    In Proc. IEEE/CVF Winter Conf. on Applications of Computer Vision (Round 2 New Submission Acceptance Rate: 26.88%) (WACV), 2026

2025

  1. Figure from Toward Embedded LLM-Guided Navigation and Object Detection for Aerial Robots
    ICRA-LBS
    Toward Embedded LLM-Guided Navigation and Object Detection for Aerial Robots
    Richie R Suganda★ and Bin Hu
    In 2025 IEEE International Conference on Robotics and Automation Late Breaking Session (ICRA-LBS), 2025

2022

  1. Figure from Energy Minimization for Federated Asynchronous Learning on Battery-Powered Mobile Devices via Application Co-running
    ICDCS
    Energy Minimization for Federated Asynchronous Learning on Battery-Powered Mobile Devices via Application Co-running
    Cong Wang, Bin Hu, and Hongyi Wu
    In 2022 IEEE International Conference on Distributed Computing Systems (Acceptance Rate: 19.9%) (ICDCS), 2022

Funded projects

  • NVIDIA Academic Grant Program Heterogeneous Multi-Robot Waste Detection with Conformal Runtime Monitoring 2026 PI